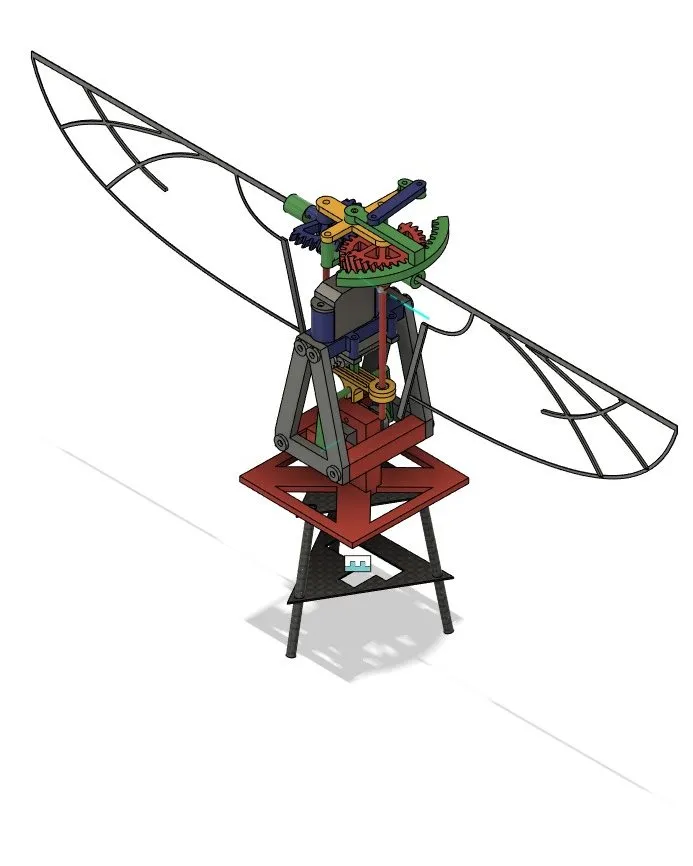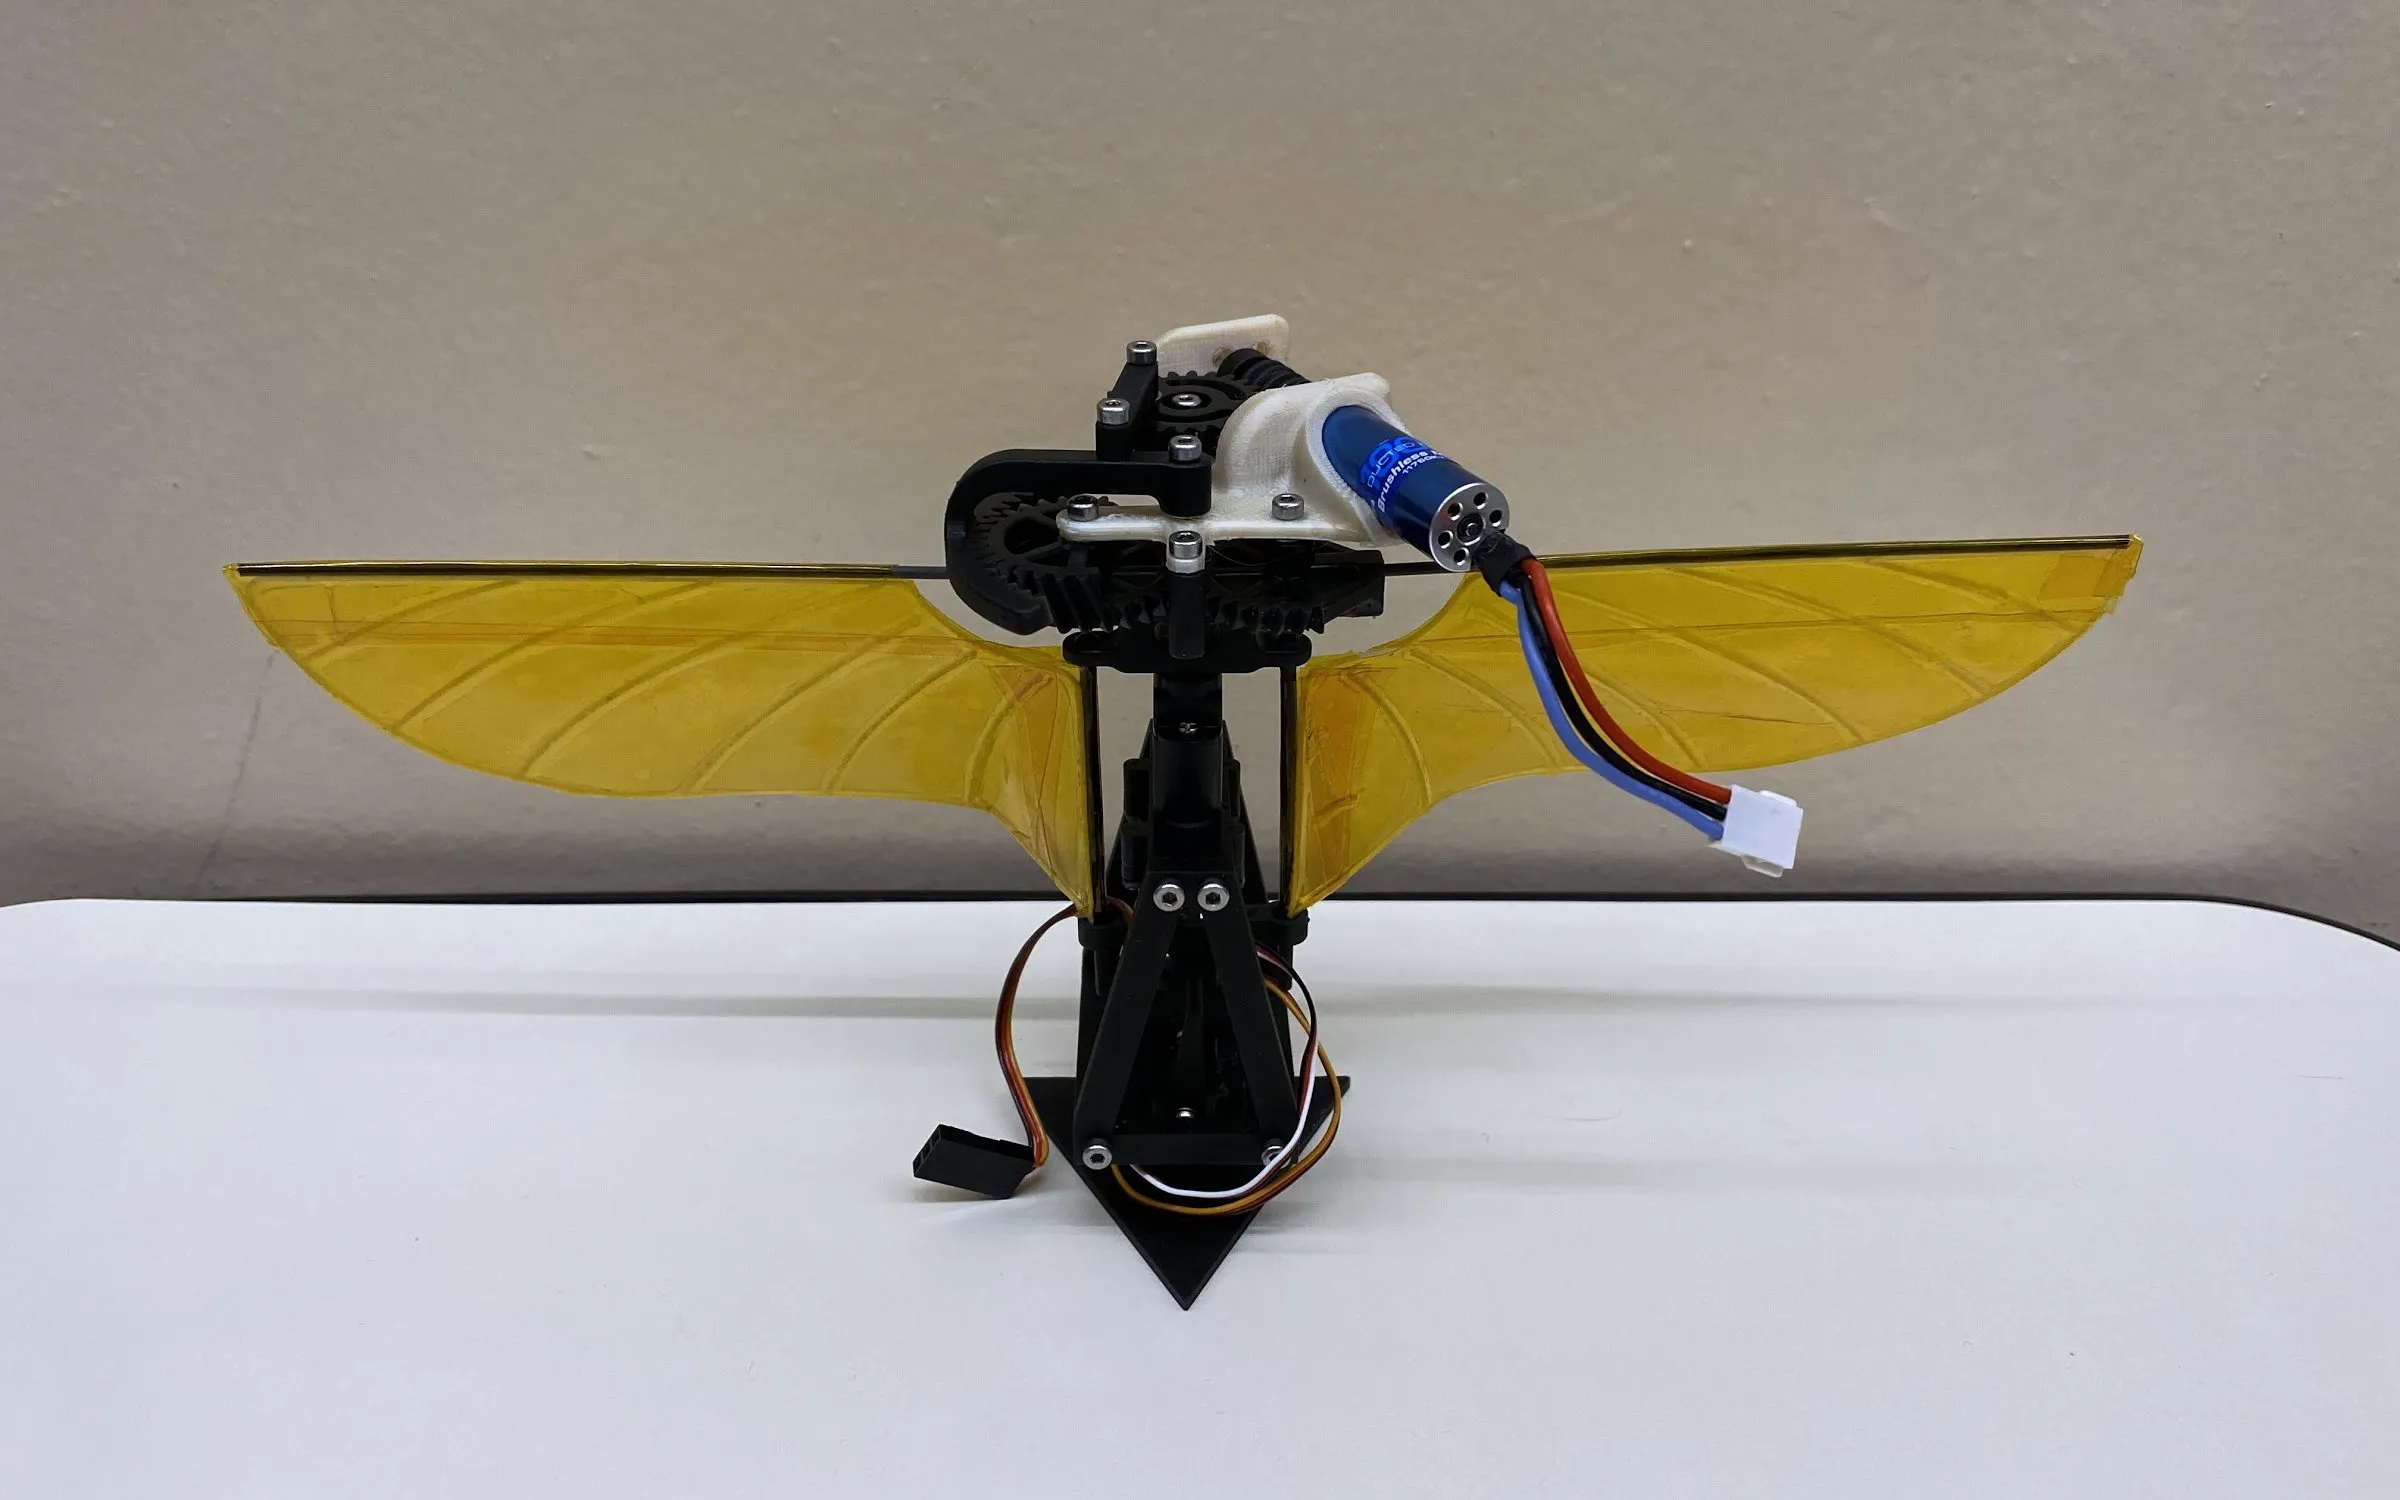
The goal of the capstone was a bio-inspired, autonomous flapping-wing flyer under 40 grams. The work was split across teams, and I was in charge of the wings.
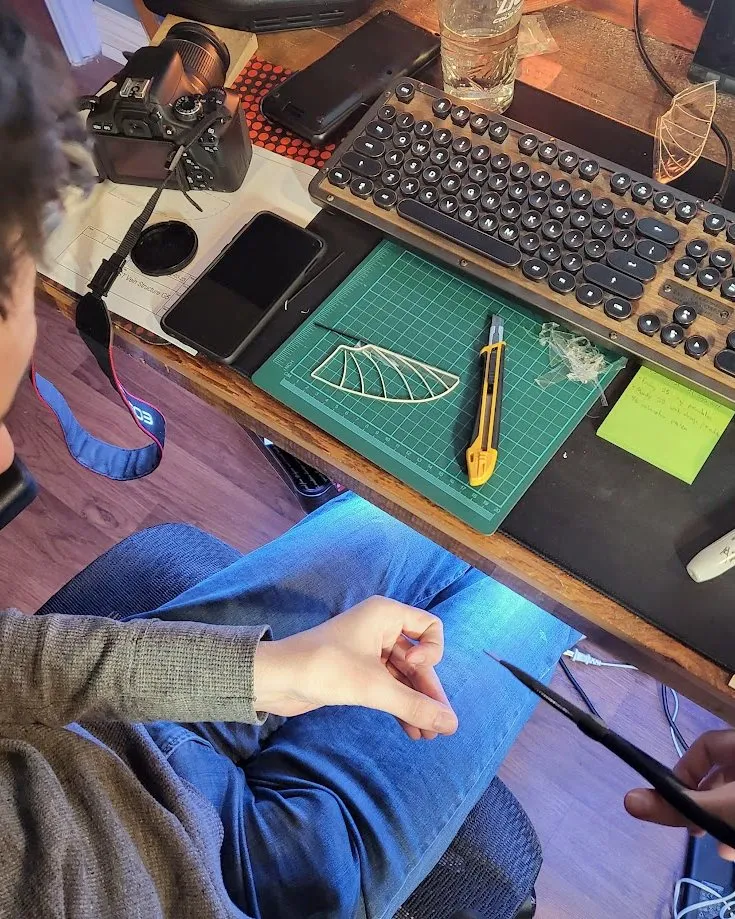
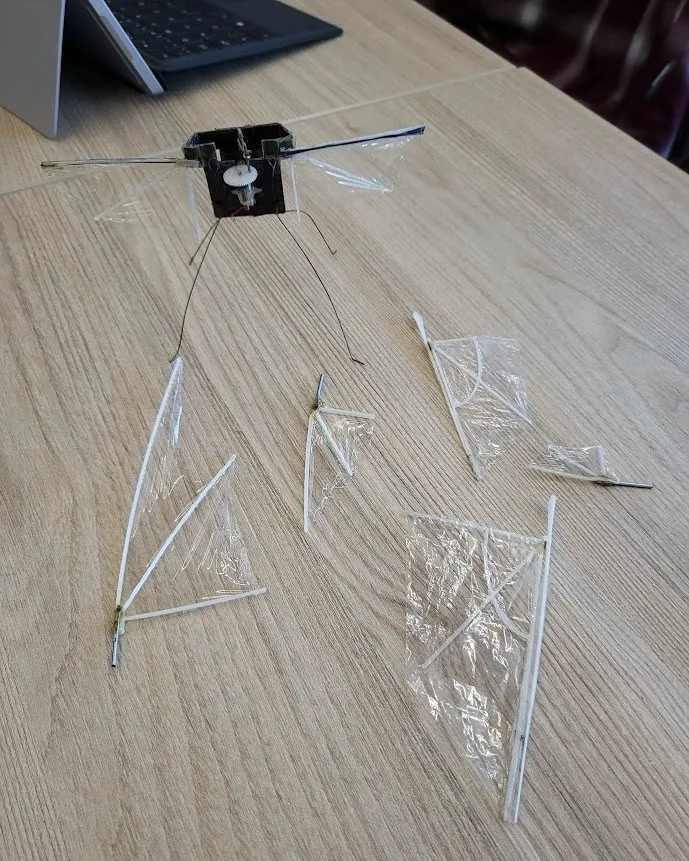
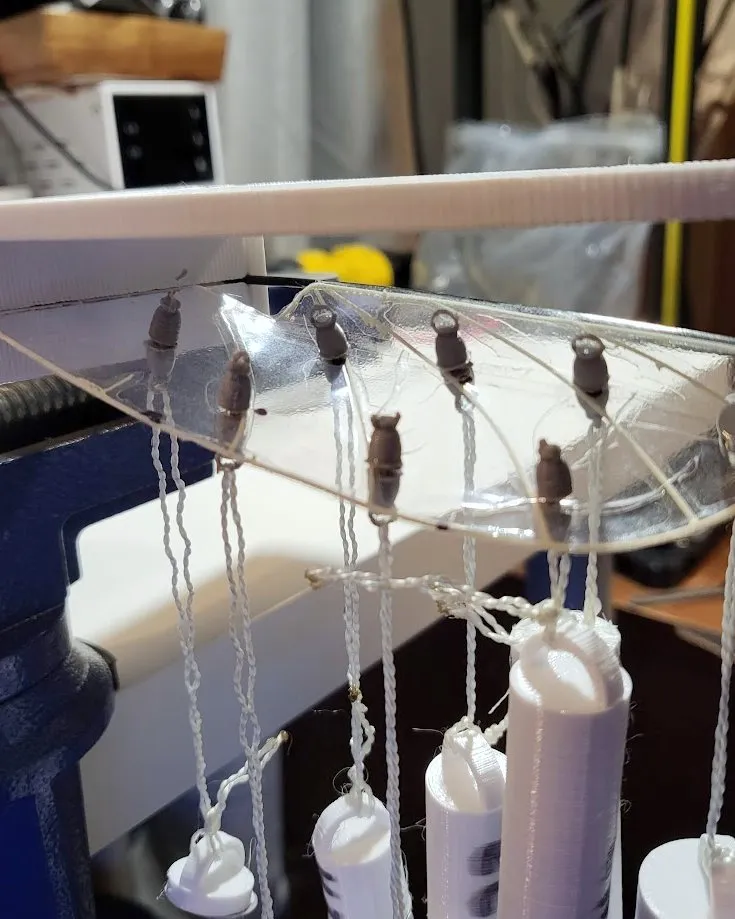
The wings had to be light but durable enough to survive continuous flapping, and predictable enough to reliably lift and control the flyer. Their stiffness had to balance lift against controllability. I designed, built, tested and iterated through several pairs, and developed a flexural test method to compare their stiffness. Then I integrated the final wings with the servo control bars. I also consulted on the servo control section and the rocker flapping mechanism.
The final wings stayed inside the wingspan and weight limits and met the integration requirements set by the other teams.
We never got powered flight while I was on the project: the batteries were always too heavy, and the 3D printed gears lost too much. After I left, the team got it flying with machined low-friction parts and external power.